S1.12 · 70° Transition Angle · October 24, 2026
S1.12 flew at a 70° transition angle twice in one day.

We’re on a mission to reshape where people live.
Join usOn October 25, S1.12 flew five times. The first three flights aimed for 70° while we tuned pitch control. On flight 4, S1.12 reached a 75° transition angle at about 40 knots, then returned to hover. That's our highest transition angle yet, up from 70° on October 24.
Gusty wind ended the day after flight 5. This video is flight 4, in light wind.
S1.12 flew at a 70° transition angle twice in one day.
S1.12, the S1.11 airframe on updated flight software, held pitch much better at a 40° transition angle and was cleared to try 50°.
S1.11, our new airframe, flew seven times at a 40° transition angle on its second day, and landed normally every time.
S1.10 reached a 50° transition angle and held it for about 13 seconds, with a top airspeed of 40 knots (46 mph). Later that day, stepping up to 70°, it crashed.
S1.10 reached a 40° transition angle for the first time, with nearly 30 knots (33 mph) of airspeed, in winds of 5 knots gusting to 6, and landed safely on all eight flights that day.
S1.10 stepped back up to a 30° transition angle three days after the S1.9 crash, in winds of about 7 to 10 knots at flight height.
S1.9 reached a 30° transition angle across six flights in one morning, averaging about 30 km/h airspeed and landing safely in winds of roughly 15 to 19 km/h at altitude.
First 15° wing tilt, filmed from the ground with the onboard camera inset. A yaw disturbance right after reaching 15° is what we're debugging now.
S1.9 started transition testing: its wings tilted 10° forward from hover and back. This full flight is filmed from the onboard camera, with pilot-input and measured-attitude overlays.
Five days after an 18G+ crash, S1.8 flew our best hover yet: precise 90-degree turns, far less motor thrust spent on yaw, and cooler motors. This full flight includes pilot-input and measured-attitude overlays.
S1.7 completed its first altitude-mode box pattern, less than two weeks after S1.5's first hover. We've gone from unwanted turning and drift to controlled hover maneuvers.
Across five flights, automatic yaw surface assistance improved heading control and tuning changes improved hover consistency. This complete final flight includes pilot-input and measured-attitude overlays, a roll maneuver, an altitude-mode test and the landing.
Successful piloted hover with five heading changes and substantially improved yaw response. Persistent left yaw still required pilot correction.
Successful first test in relatively still air. Wind prevented the planned yaw tuning and control-surface tests later in the session.
Turning response felt better after adjusting the controls, but unwanted turning and drift remained. We consider this test successful, even with the hard landing. No appreciable damage, just light repairs with an expected one-day turnaround.
We flew a short hover test. It was a reasonable first hover, with no appreciable damage. Unwanted turning and drift still required attention.
We were testing simpler firmware, a new landing gear design and tilt mechanism design. It was unsuccessful and ended in a hard landing.
S1.4 lifted off, but the hover attempt was unsuccessful. We returned to ground testing before trying again.
S1.3 lifted off and hovered. The test ended in a light crash that damaged that airframe.
S1.2 completed stabilized roll and pitch maneuvers in winds gusting up to 16 mph.
S1.2 completed its first hover, including liftoff, hover, and touchdown.
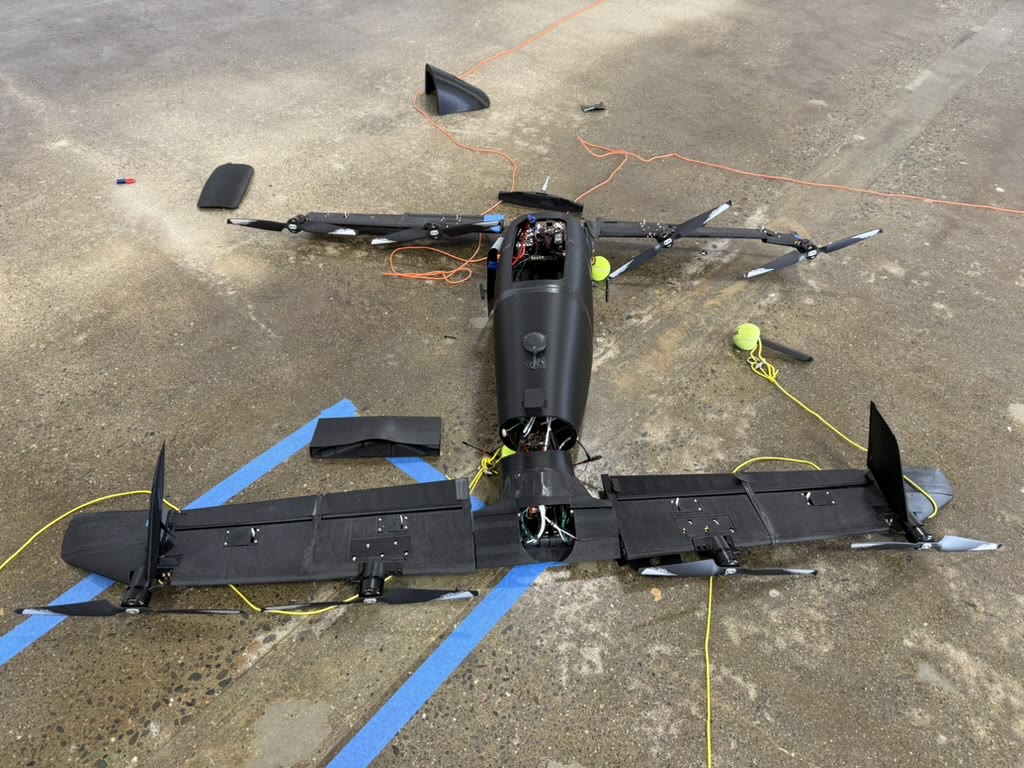 S1.1
Hover attempt
S1.1, our first 20%-scale prototype, lifted off, but a control-software configuration issue drove half the motors higher as the aircraft tried to correct its yaw. We then iterated to S1.2, a hover-only airframe built to prove out hover faster.