S1.7 · First Altitude-Mode Box Pattern · September 19, 2026
S1.7 completed its first altitude-mode box pattern, less than two weeks after S1.5's first hover. We've gone from unwanted turning and drift to controlled hover maneuvers.
Aircraft speed. Car-like freedom.
Join usFive days after a crash with over 18G of impact force, S1.8 flew our best hover yet. We didn't need to replace any parts; the only repair was an added composite ply over a crack in the fuselage.
The share of motor thrust spent on yaw dropped to 3 to 6 percent, from as much as 60 percent before the crash. After each 90-degree turn, the aircraft held heading within 0.3 degrees, and the motors ran 15 to 20°C cooler. Winds were light, so we still need to confirm this in stronger wind. In a second flight, forward speed in the hover configuration topped out at about 3 to 4 m/s, short of what the box pattern needs.
S1.7 completed its first altitude-mode box pattern, less than two weeks after S1.5's first hover. We've gone from unwanted turning and drift to controlled hover maneuvers.
Across five flights, automatic yaw surface assistance improved heading control and tuning changes improved hover consistency. This complete final flight includes pilot-input and measured-attitude overlays, a roll maneuver, an altitude-mode test and the landing.
Successful piloted hover with five heading changes and substantially improved yaw response. Persistent left yaw still required pilot correction.
Successful first test in relatively still air. Wind prevented the planned yaw tuning and control-surface tests later in the session.
Turning response felt better after adjusting the controls, but unwanted turning and drift remained. We consider this test successful, even with the hard landing. No appreciable damage, just light repairs with an expected one-day turnaround.
We flew a short hover test. It was a reasonable first hover, with no appreciable damage. Unwanted turning and drift still required attention.
We were testing simpler firmware, a new landing gear design and tilt mechanism design. It was unsuccessful and ended in a hard landing.
S1.4 lifted off, but the hover attempt was unsuccessful. We returned to ground testing before trying again.
S1.3 lifted off and hovered. The test ended in a light crash that damaged that airframe.
S1.2 completed stabilized roll and pitch maneuvers in winds gusting up to 16 mph.
S1.2 completed its first hover, including liftoff, hover, and touchdown.
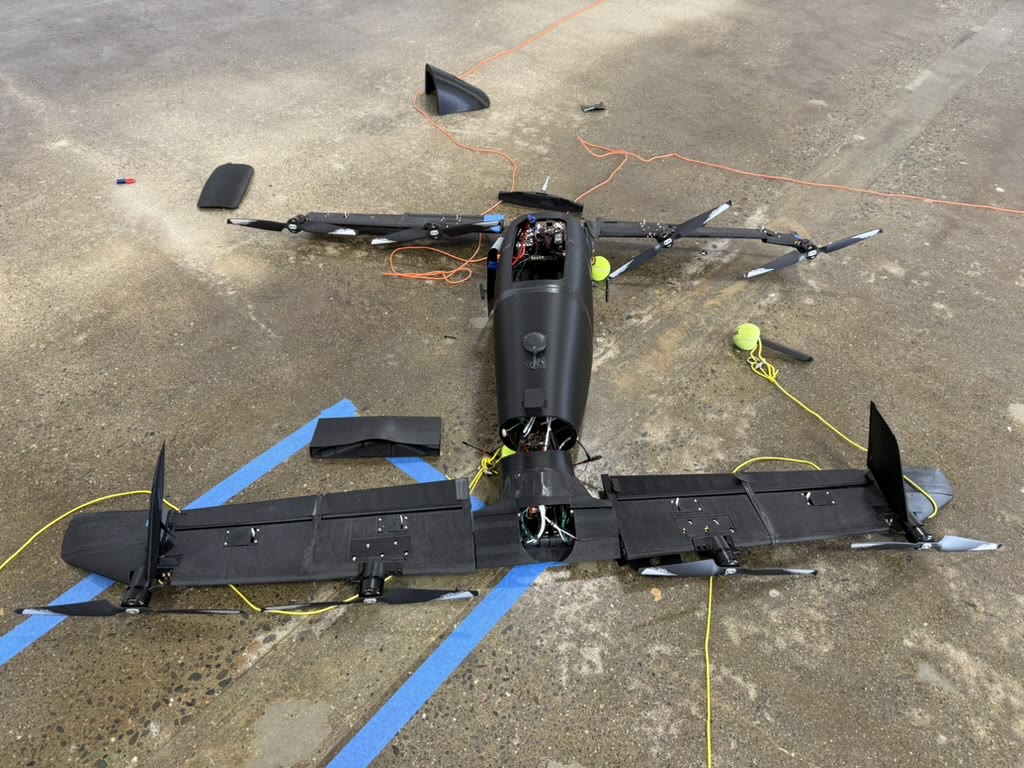 S1.1
Hover attempt
S1.1, our first 20%-scale prototype, lifted off, but a control-software configuration issue drove half the motors higher as the aircraft tried to correct its yaw. We then iterated to S1.2, a hover-only airframe built to prove out hover faster.
Watch new tests and get announcements for upcoming streams.